Research
CORe
Research Objective 03
Human-Machine Intelligent Systems
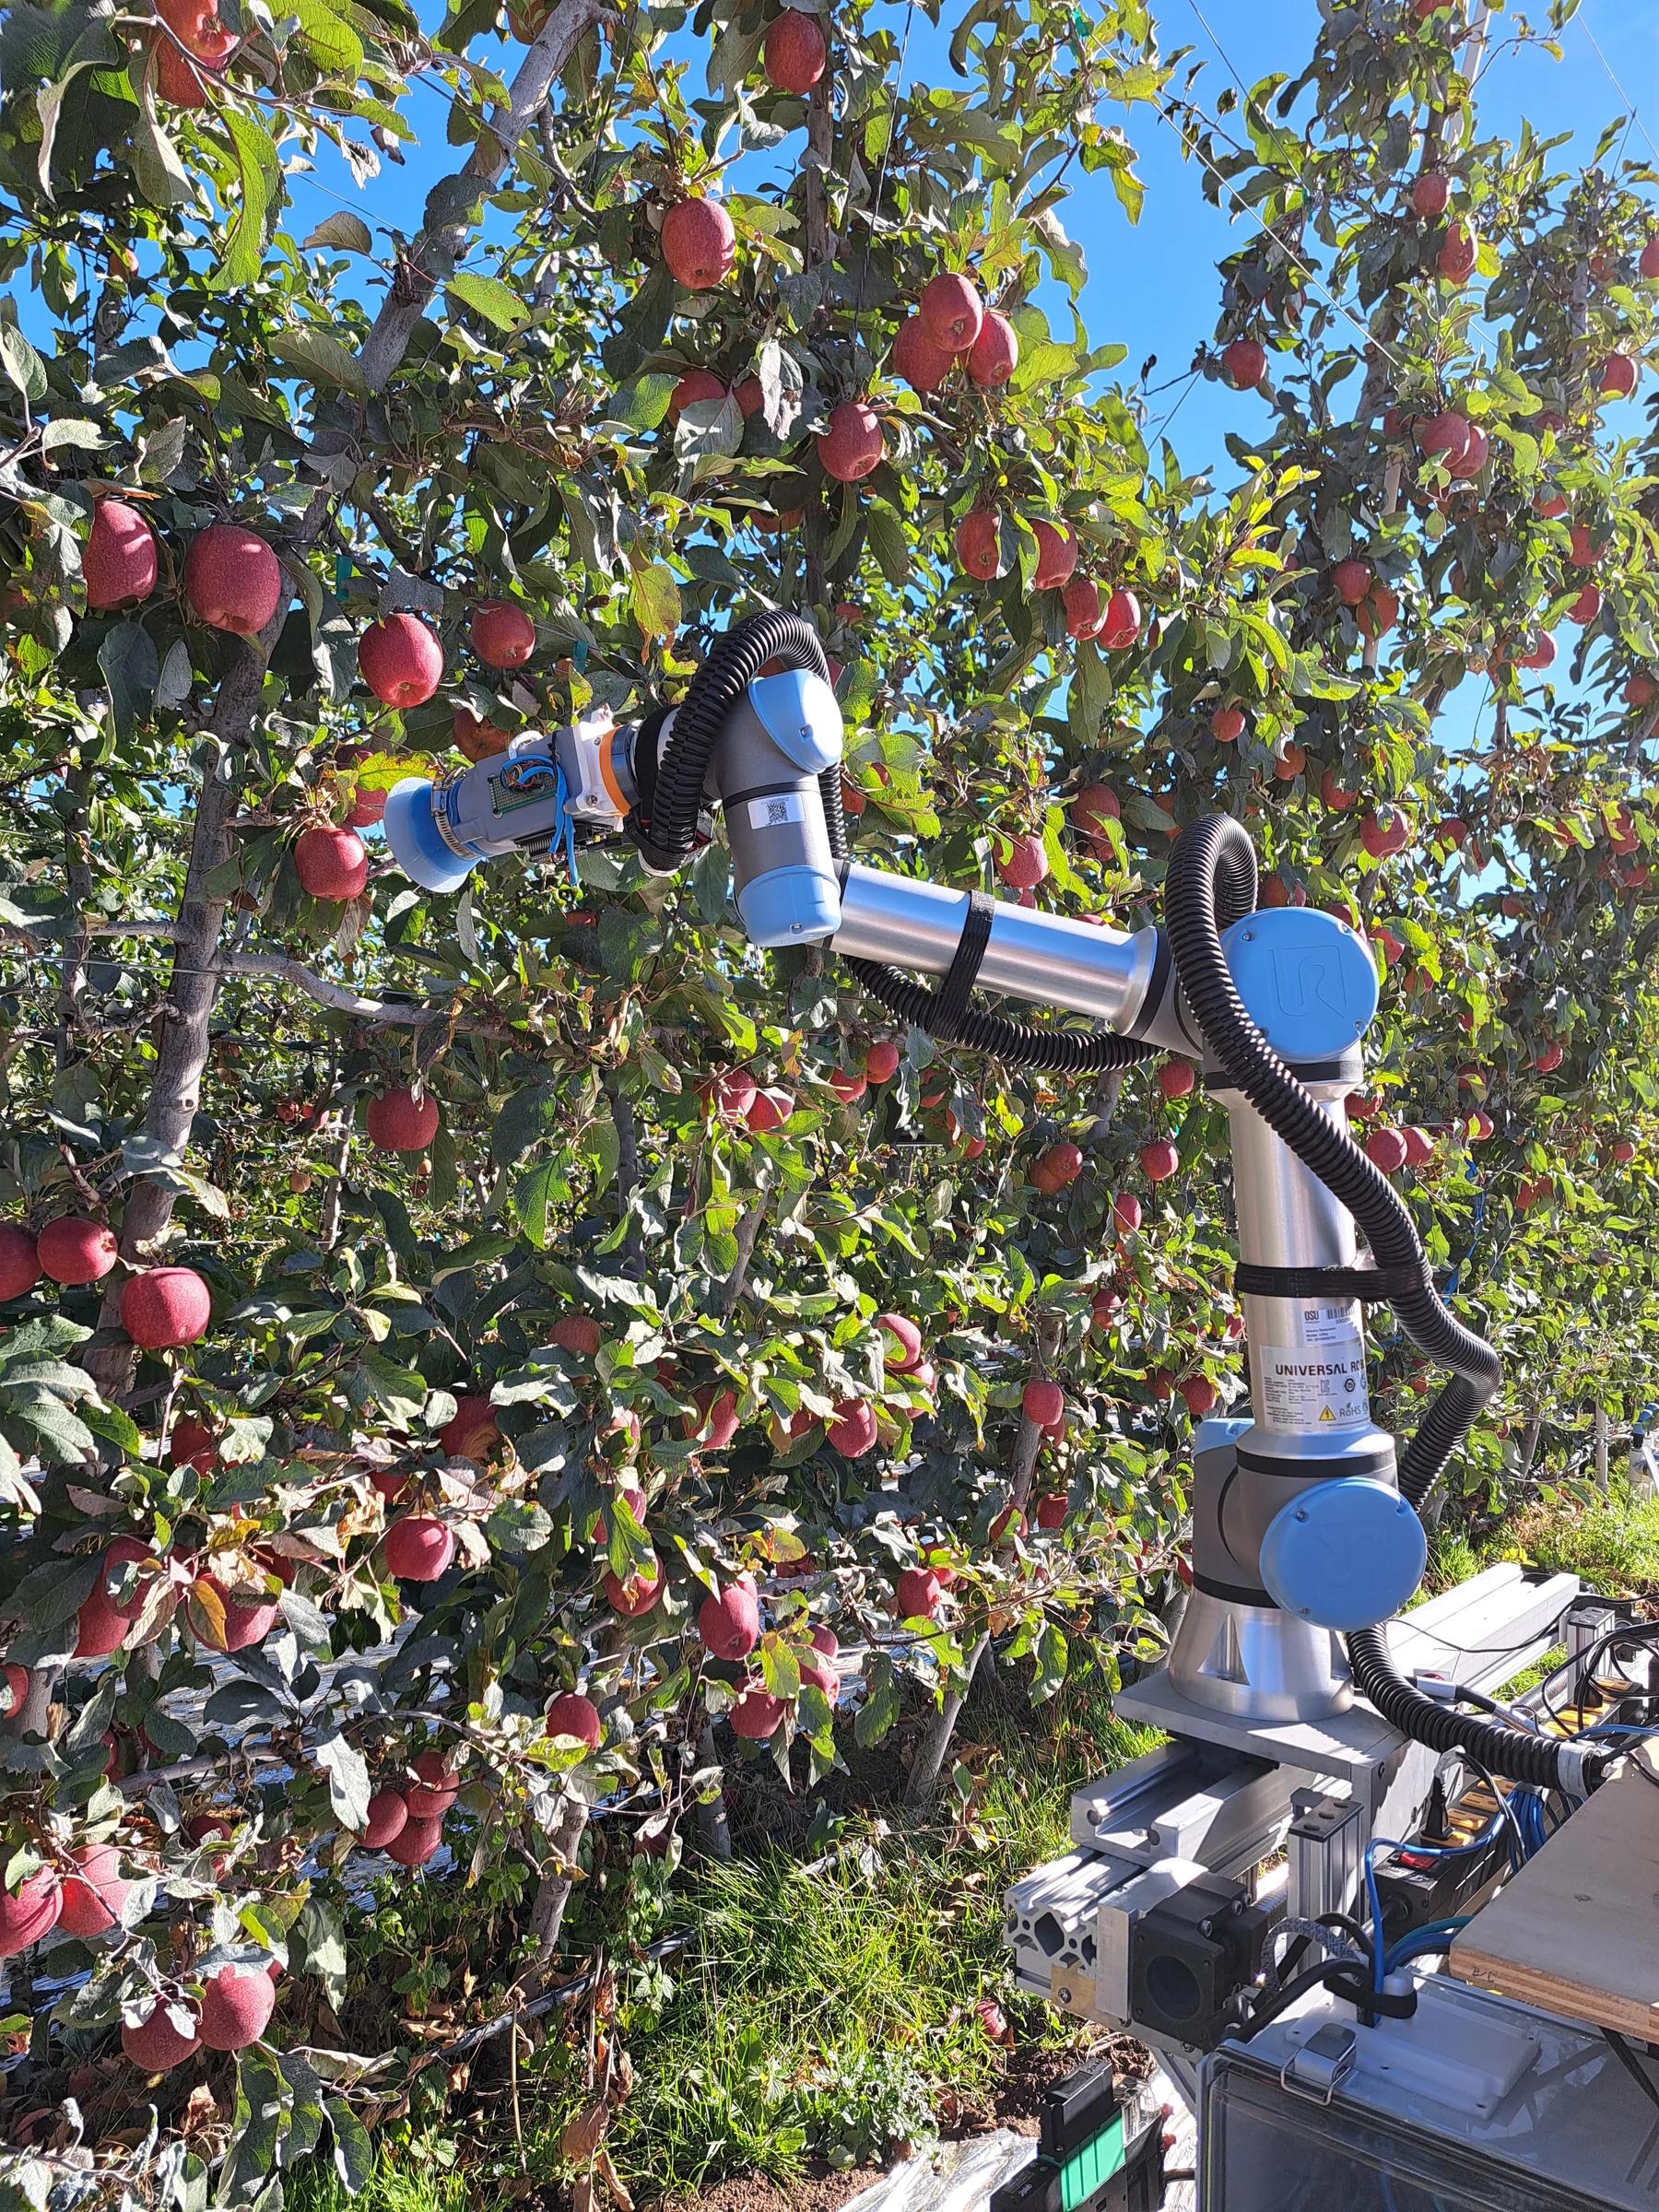
Developing and evaluating multi-purpose robotic systems and associated perception, manipulation, control and integration technologies.
The challenge
Labor-intensive orchard operations demand systems that can work reliably in complex biological environments and support more than one seasonal task.
01
Integrated systems
The planned work connects sensing, manipulation, control and human-machine interaction.
Tree-canopy perception
Robotic hands and manipulators
Path planning and control
Human-in-the-loop decisions
02
Multi-purpose robotics
Components will be integrated and evaluated as orchard robotic systems.
Harvesting and flower thinning
System integration
Laboratory evaluation
Commercial-orchard field evaluation